01Robotics / Embedded
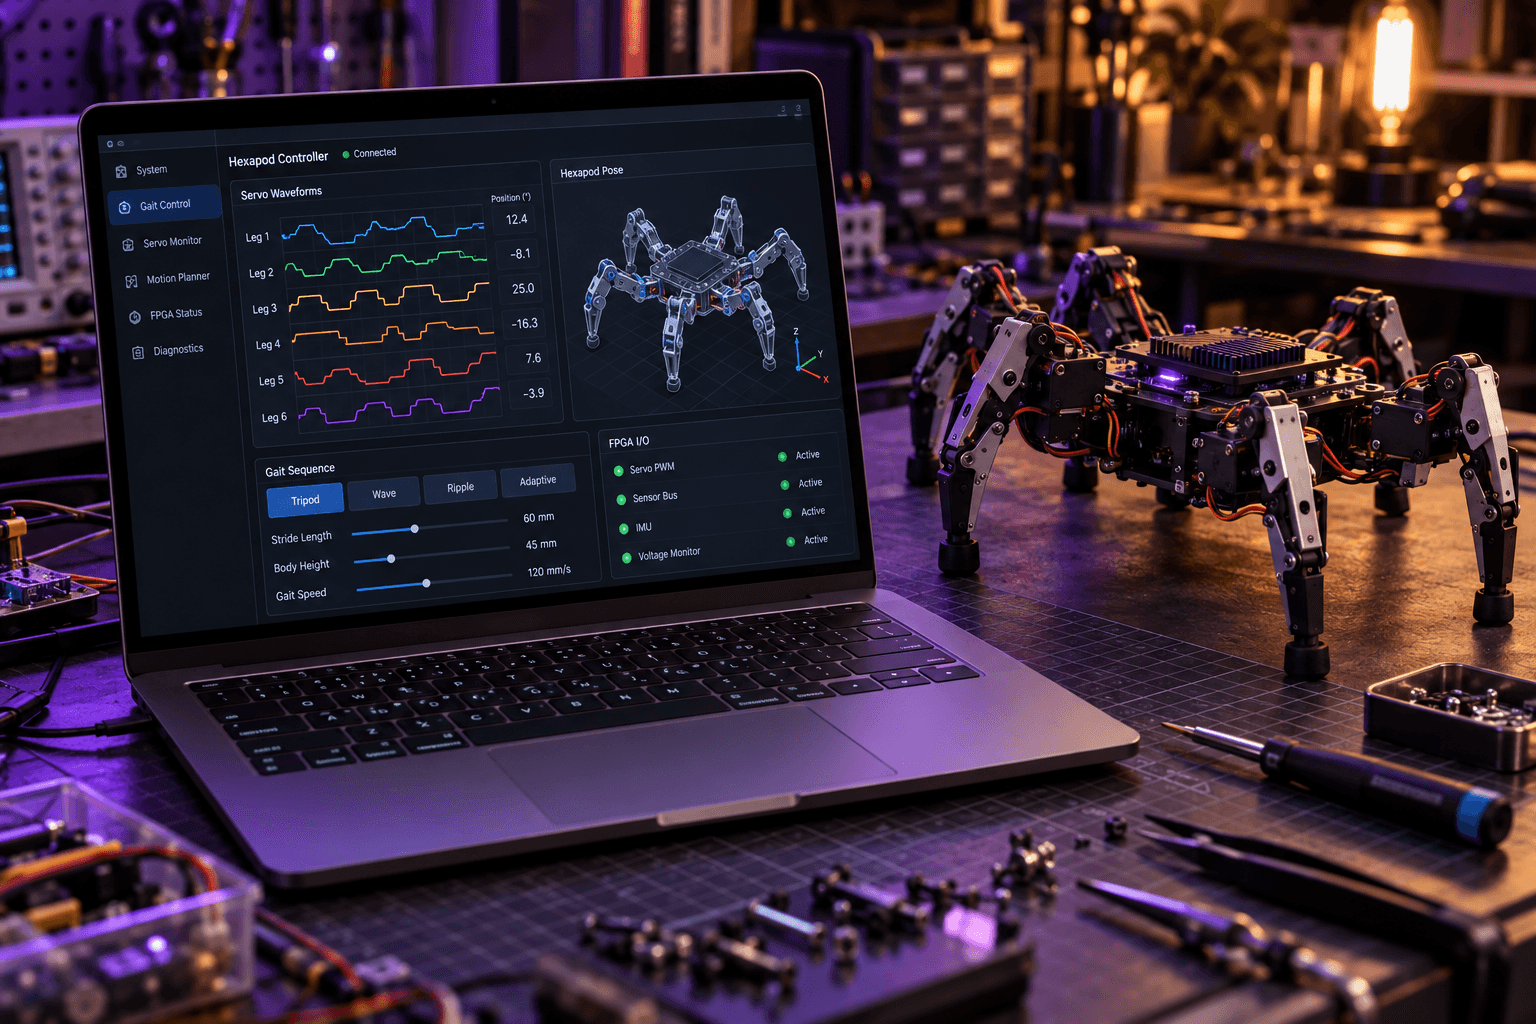
FPGA-Controlled Hexapod Robot
FPGA-based PWM generation and push-button control for the Spider robot, progressing from a single servo to independent control of three joints on one leg.
FPGAPWMQuartusServo Control
View Project Projects
Exploring hardware, software, and the signals that connect them—through design, implementation, and testing.
01 / Featured projects
A closer look at the systems I’ve built and the engineering behind them.
FPGA-based PWM generation and push-button control for the Spider robot, progressing from a single servo to independent control of three joints on one leg.
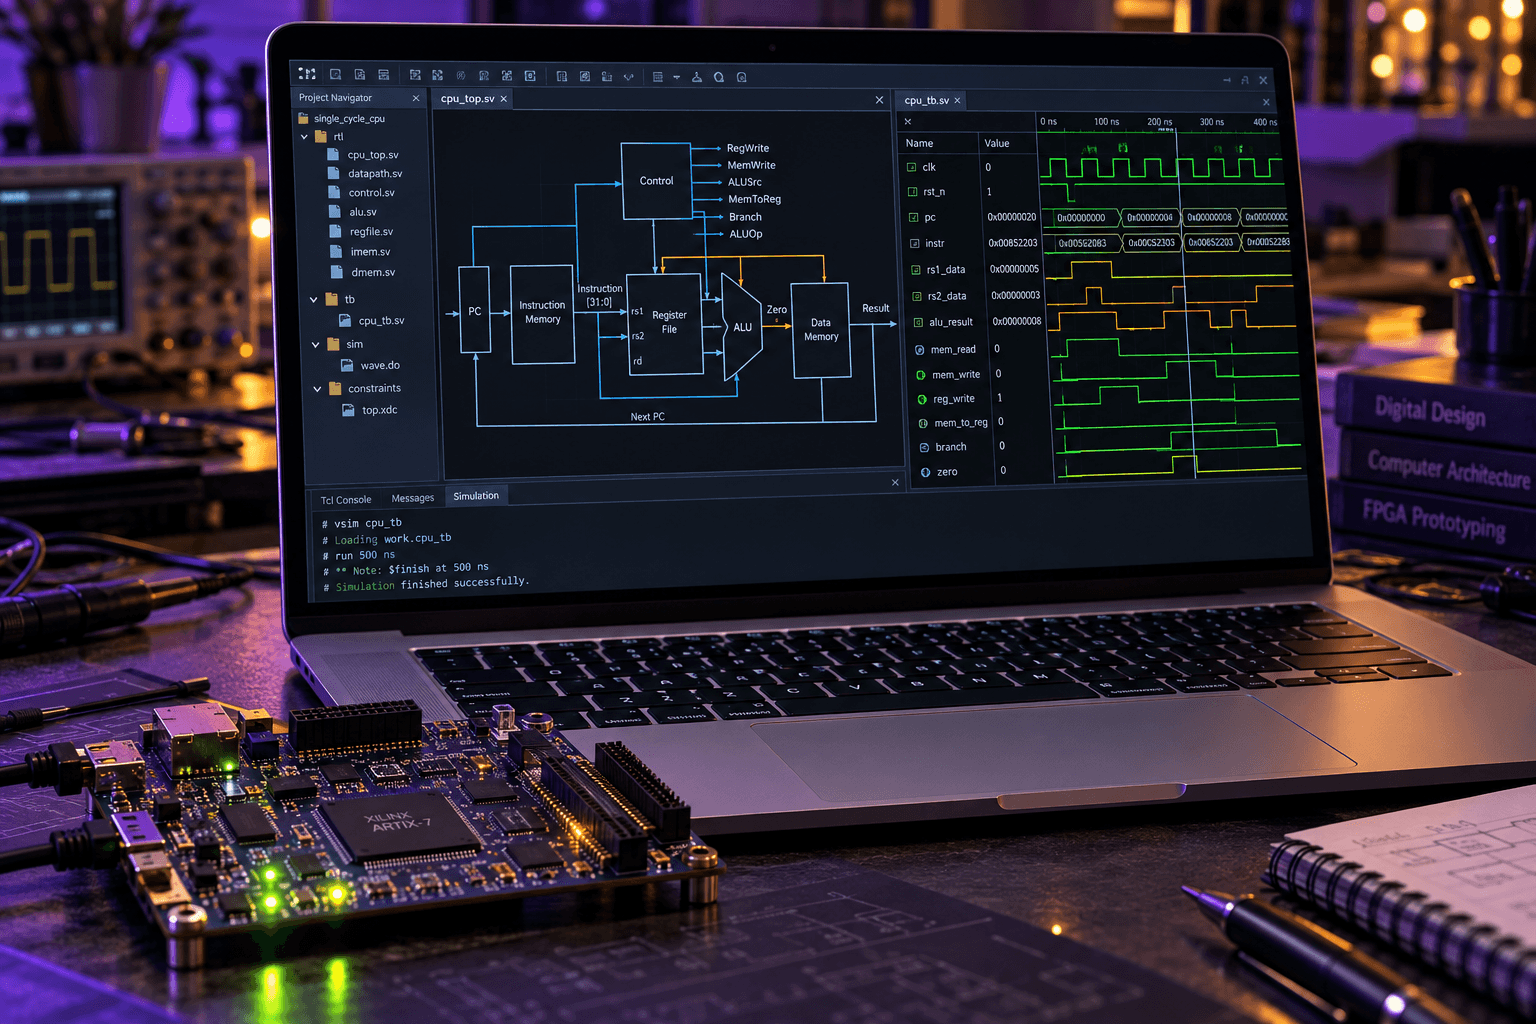
Designed and implemented a single-cycle processor on a Xilinx Zynq FPGA, integrating the datapath, control logic, register file, memory, instruction decoding, and branching.
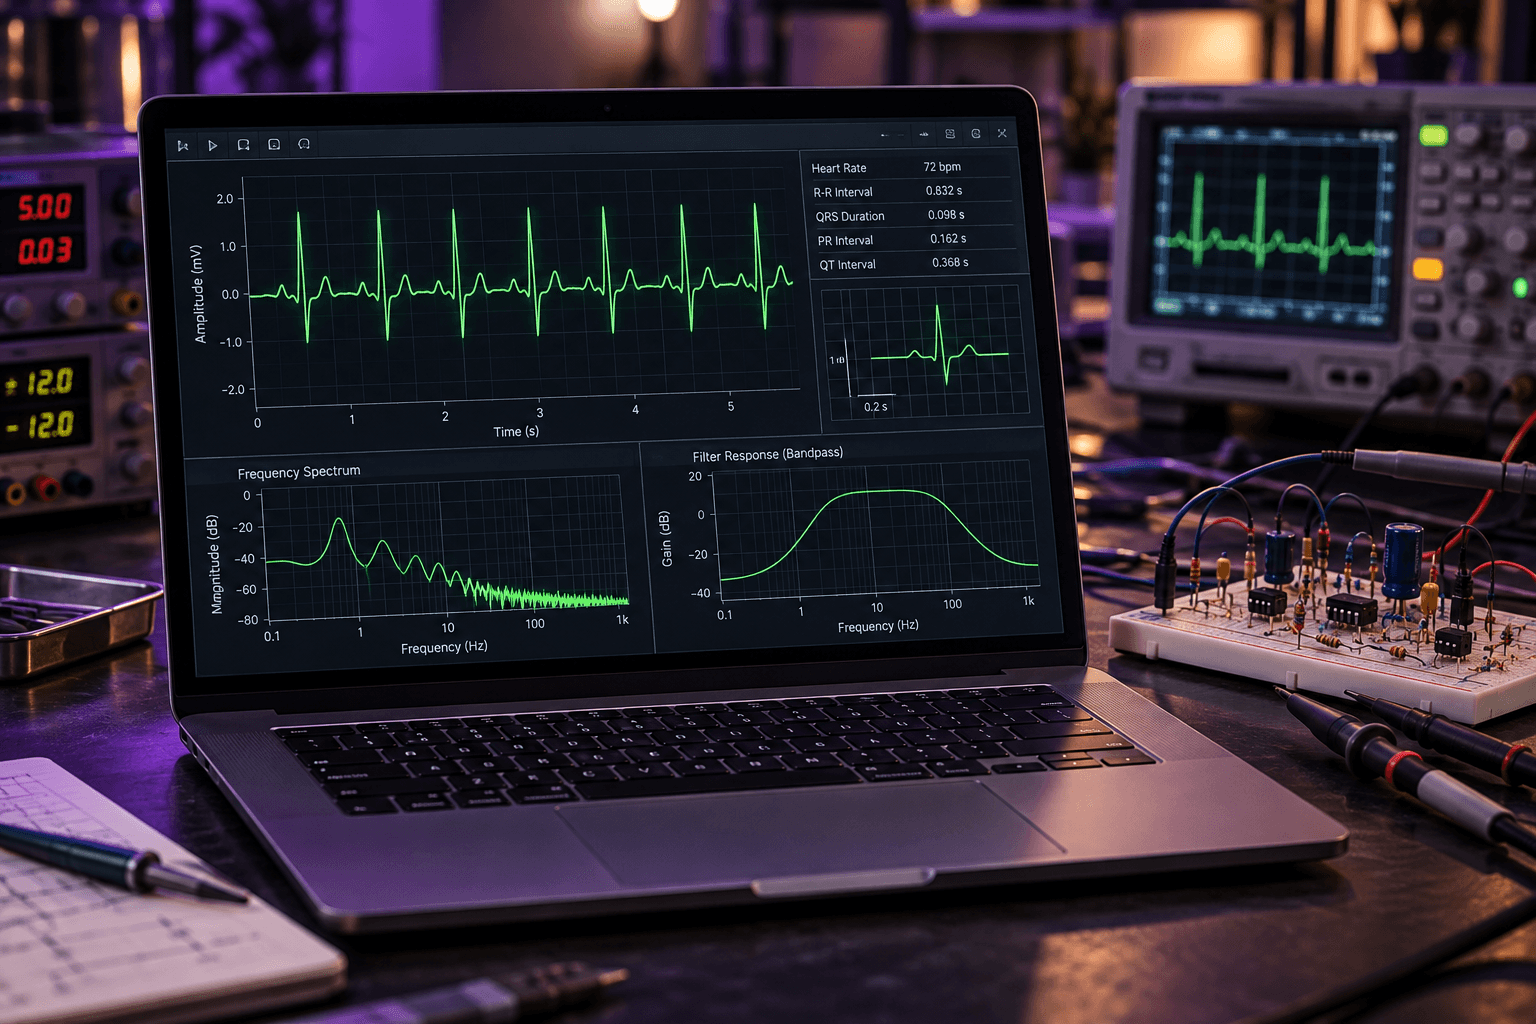
Investigated ECG amplification and analog filtering with an AD627 instrumentation amplifier, LT1490 active filters, and preparation for data acquisition.
02 / Further explorations
Hands-on investigations in circuit behavior and electronics.
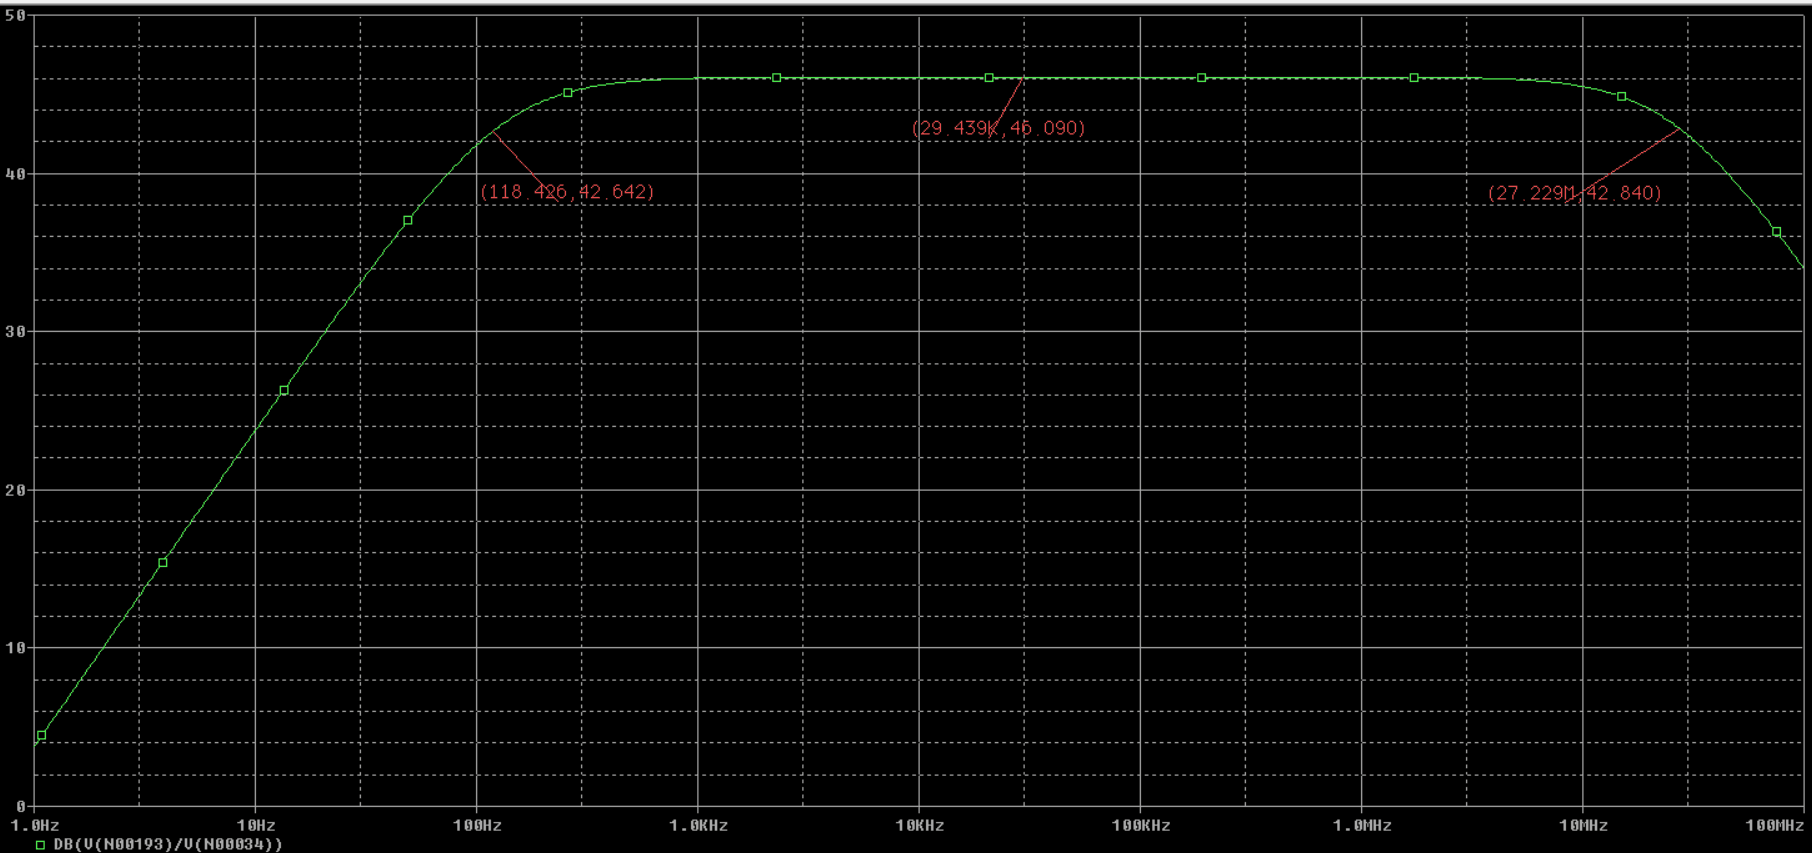 Original simulation · EECE 2413
04 / Analog & electronics
Built, measured, and simulated analog circuits across op amps, BJT amplifiers, diodes, and MOSFET/CMOS devices in EECE 2413.
Explore the case studyKeep exploring
See how academic work connects with my co-op experience.